Related News
- 00
0000-00
How Seat Belt Pretensioners and Load Limiters Work Together in a Crash - 00
0000-00
Hot Stamping for BIW: How Die Quenching Controls Strength and Dimensional Accuracy - 00
0000-00
Product Selection Resources for Sourcing: How to Compare Specs and Samples - 00
0000-00
Choosing a Hot Stamped Steel Components Exporter: PPAP and Traceability Checks - 00
0000-00
Sourcing Automotive Body Stampings for OEMs: Tooling, PPAP, and Capacity Checks
Navigation Tech Scientist
Weekly Insights
Stay ahead with our curated technology reports delivered every Monday.
What Causes Inaccurate Maritime Navigation Data?





A vessel can appear to be exactly on track while the navigation display is quietly working from a wrong position, an old chart object, a misaligned heading source, or a delayed target feed. The immediate effect may be small: a track line shifted from the channel center, a buoy that does not line up with the radar return, or an AIS target that seems to drift. In confined water, near offshore structures, or during reduced visibility, those small differences can become operationally significant.
What causes inaccurate maritime navigation data? Usually, the error comes from one or more of five places: the positioning signal, onboard sensors, chart and database content, data integration or timing, and human setup or interpretation. The practical response is not to trust a single display or immediately assume one device has failed. Compare independent sources, identify whether the discrepancy is positional, directional, temporal, or chart-related, and then isolate the inputs that create it.
Start by identifying what looks wrong
“Inaccurate navigation data” is not one fault condition. A GPS position can be plausible but offset from the vessel’s radar overlay. The position may be correct while the displayed heading is wrong. An electronic chart may be valid but missing a recently changed aid to navigation. Separating these symptoms prevents wasted troubleshooting.
A useful principle is to ask whether the error moves with the vessel, remains fixed against charted land, or appears only when a particular layer is switched on. A fixed offset can point to an antenna location or datum issue. A changing error may indicate signal degradation, heading instability, or delayed data. A mismatch visible only in an overlay often originates in the overlay’s input stream rather than the underlying chart.
Satellite positioning is accurate only when the signal environment is healthy
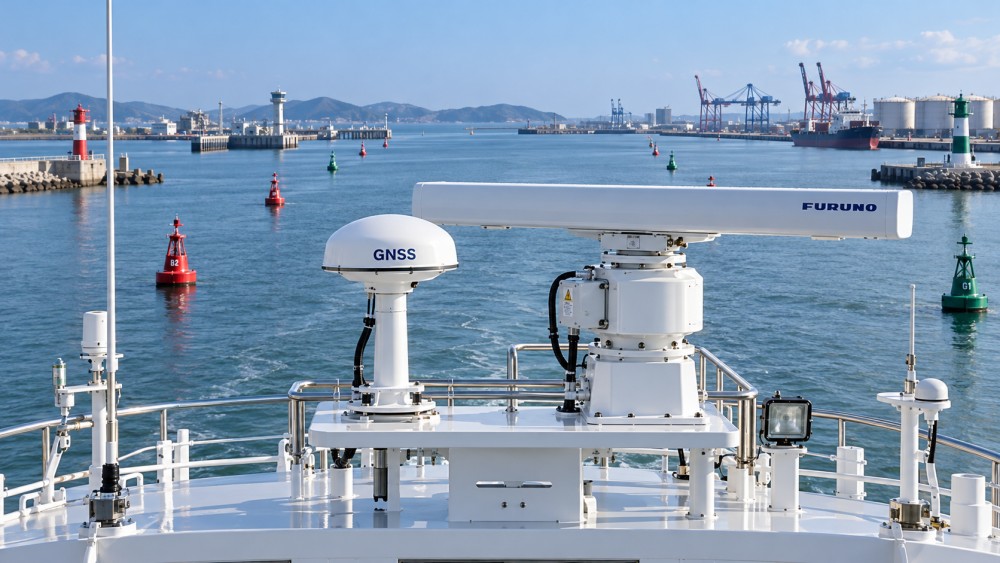
GNSS receivers calculate position from weak signals arriving from satellites. Their performance can be affected by blocked sky view, reflected signals, atmospheric effects, antenna problems, receiver configuration, and intentional or unintentional radio-frequency interference. Open-water conditions often provide a good view of the sky, but bridge structures, masts, cranes, high terrain, port infrastructure, and nearby metal surfaces can still affect reception.
Interference, jamming, and spoofing
Jamming reduces a receiver’s ability to track satellite signals. The practical signs can include loss of position, degraded accuracy indicators, frequent source switching, or intermittent alarms. Spoofing is more deceptive: a receiver may continue to report a believable position even though it is being led away from the vessel’s true location. A steadily moving position that conflicts with radar, visual navigation, depth trends, or a separate receiver deserves immediate attention.
Do not treat a functioning latitude and longitude display as proof that the position is trustworthy. Check the receiver’s status page for satellite availability, differential corrections where applicable, integrity alerts, antenna status, and source selection. Compare position with radar ranges and bearings to recognizable features when conditions permit. On vessels equipped with multiple independent sources, determine whether they agree before deciding that the chart or radar is at fault.
Multipath and antenna installation
Multipath occurs when a satellite signal reflects from a surface before reaching the antenna. The receiver processes a mix of direct and reflected signals, which can distort the calculated position. Metal structures, wet decks, nearby antennas, and poorly chosen mounting locations can increase this risk. A damaged cable, corroded connector, water intrusion, weak power supply, or incompatible antenna can produce similarly erratic behavior.
The antenna also has a physical location. Navigation systems need the correct offset from the vessel reference point, often called the conning position or reference point. An incorrect offset may not matter in open water, but it can be conspicuous during docking, lock transit, dredged-channel work, or close-quarters maneuvering. Verify the entered fore-and-aft, port-starboard, and vertical offsets against the actual installation rather than relying on an old commissioning record.
Heading errors can make good position data look bad
Many navigation displays combine position with heading to orient the chart, stabilize radar, calculate vectors, and overlay one sensor on another. A heading source that is misaligned, unstable, or selected incorrectly can therefore create a misleading picture even when the GNSS position itself is sound.
Course over ground is not the same as heading. Course over ground describes the vessel’s actual movement over the seabed; heading describes where the bow is pointed. Current, wind, leeway, and maneuvering create differences between the two. A system configured to use course over ground as a substitute for heading may look acceptable while moving steadily in calm water, then become unreliable at low speed, while turning, or when set and drift are present.
Gyrocompasses, magnetic compasses, satellite compasses, and rate sensors each have installation and operational limits. A consistent angular mismatch between radar returns and charted features can indicate heading alignment error. A rapidly changing mismatch may point to a failing heading input, poor stabilization, a network message issue, or the wrong source being prioritized by the display.
Check the selected heading source, then compare the reported heading with an independent compass and with known visual alignments where safe and practical. Radar bearing alignment should be verified using suitable fixed objects and documented procedures. Avoid “correcting” a chart display until the underlying heading and position inputs have been checked; compensating for one hidden error can make a later fault harder to recognize.
Charts can be current, but still unsuitable for the decision being made
Electronic charts are not a live picture of the sea. They are structured datasets based on surveyed information, published notices, chart compilation choices, and display settings. Even an updated Electronic Chart Display and Information System can present an incomplete operational picture if its updates have not been properly applied, its safety settings are wrong, or essential temporary information has not been considered.
Outdated chart permits, failed update downloads, interrupted installation, and an incorrect chart catalogue can leave a system using superseded information. The problem is not always obvious because the chart still loads normally. Confirm the edition and update status of charts relevant to the intended route, including approach areas, anchorages, terminals, and contingency locations.
Equally important is the display configuration. Safety contour, safety depth, shallow-water contour, deep-water contour, look-ahead parameters, and route-check settings must reflect the vessel’s actual draft, squat considerations, operational margin, and the voyage context. A chart may contain a danger that is filtered, de-emphasized, or not generating the expected alert because the setup is inappropriate.
Chart datum mismatches can also cause confusion. GNSS positions are commonly referenced to a global geodetic datum, while local chart data and sensor readings may require specific transformations or datum awareness. Modern electronic systems manage much of this automatically, but operators should not assume every imported waypoint, legacy paper reference, local coordinate, or third-party dataset uses the same basis.
Data networks can introduce delay, loss, and conflicting sources
Modern bridges often combine GNSS, gyro, log, wind, echo sounder, AIS, radar, autopilot, and chart data over serial connections or networked interfaces. The display may show a coherent picture even when one feed is delayed, malformed, duplicated, or being replaced by an unintended backup source.
Latency matters most when the vessel is moving quickly, turning, or operating close to hazards. A delayed position can shift an overlay behind the actual scene. A delayed heading feed can make radar trails and chart alignment appear inconsistent. AIS data may be older than the displayed screen time, particularly when reception is intermittent or messages are not being received at the expected interval. The symbol is useful for awareness, but it should not be treated as a precise, real-time collision-avoidance reference.
Source priority should be reviewed after equipment changes, software updates, maintenance, or power interruptions. Some systems automatically revert to another available input when a preferred source fails. That fallback can preserve continuity, yet it may have different accuracy, datum, latency, or antenna offset characteristics. Record which source is active, not merely which sources are connected.
Sensor faults often begin as small inconsistencies
Navigation equipment does not need to fail completely to become misleading. A depth transducer can report a plausible value while suffering from fouling, aeration, incorrect draft offset, or poor mounting conditions. A speed log may be affected by contamination or calibration drift. A compass can be influenced by nearby electrical equipment or structural changes. Temperature, vibration, moisture, and aging connectors can turn an intermittent fault into a recurring one.
Watch for patterns. Does the discrepancy begin after starting a particular generator, activating a high-power transmitter, changing steering mode, or entering a sheltered port area? Does it occur only at low speed, in heavy weather, after a long period of operation, or following a software restart? Patterns narrow the investigation more effectively than repeatedly rebooting every device.
Maintenance records should include installation changes, firmware versions, calibration dates, sensor source selections, and any known offsets. This is especially valuable when several technicians or watchkeepers work with the same equipment over time. Without a baseline, a display setting changed for one maneuver can be mistaken for a persistent equipment fault later.
Human input errors remain a major source of bad navigation information
Incorrect route data can enter the system before a vessel leaves berth. A waypoint may be copied with a digit transposed, entered in the wrong coordinate format, placed on the wrong side of a navigable channel, or imported without confirming its datum. Routes built from old information can retain obsolete turn points or unsafe cross-track limits. A visually tidy route is not necessarily a safe route.
Manual settings deserve the same scrutiny as sensors. Common examples include the wrong vessel draft, an inactive safety contour, an incorrect antenna offset, a disabled alarm, an improperly selected chart scale, or a radar range chosen too wide to reveal a close hazard. Over-zooming can hide the context needed to understand a route, while under-zooming can suppress detail that matters during a pilotage phase.
Cross-checking is not simply a regulatory habit; it is how errors become visible before they become consequential. Before a critical passage, compare the planned route against current chart information, verify safety parameters, confirm the active position and heading sources, and ensure that the radar, AIS, sounder, and visual observations are being interpreted as separate evidence rather than as copies of the same potentially flawed input.
A practical response when displays disagree
When an inconsistency appears, avoid making a rapid correction based on the display that seems most familiar. First preserve situational awareness: reduce speed or increase margin where the operating situation requires it, use visual and radar information, and avoid relying on a single questionable layer.
- Describe the discrepancy precisely. Is it a position offset, heading mismatch, delayed overlay, unreliable depth, missing chart object, or target correlation problem?
- Compare independent evidence. Use radar ranges and bearings, visual marks, a second positioning source, compass readings, soundings, and charted features as appropriate.
- Check active sources and quality indicators. Confirm which GNSS, heading, speed, and AIS inputs the display is actually using. Review alarms, satellite status, and network health.
- Inspect configuration before changing calibration. Verify datum, antenna offsets, sensor offsets, safety settings, time synchronization, and source priorities.
- Isolate the affected input. Determine whether the issue follows one sensor, one display, one overlay, or one data connection.
- Document the condition and corrective action. A record of time, location, weather, equipment state, and observed mismatch helps recurring faults be diagnosed correctly.
Some issues require qualified service support, particularly repeated GNSS loss, suspected interference or spoofing, unstable heading, failed radar alignment, network faults, or any discrepancy that cannot be reconciled with independent navigation methods. The key operational point is simple: reliable navigation comes from validating a system of information, not from assuming that one accurate-looking screen is the complete truth.
Related News
- What Causes Inaccurate Maritime Navigation Data?Oct 17, 2026What causes inaccurate maritime navigation data? Explore GNSS errors, heading faults, chart updates, sensor issues, and practical cross-checks for safer vessel operations.
- How to Evaluate Precision Marine Navigation GPS for Offshore VesselsAug 23, 2026Precision marine navigation GPS buying guide for offshore vessels: learn how to assess accuracy, interference resistance, integration, and durability before choosing a dependable system.
- Automatic Identification Systems Exporter Checklist: Certifications, Range, and Integration SupportJul 12, 2026Automatic identification systems exporter checklist covering certifications, signal range, integration support, export documentation, and after-sales service to help buyers choose with confidence.
- Navigation and Guidance Systems Explained: GNSS, Inertial Sensors, and Use-Case DifferencesJul 03, 2026Navigation and guidance systems explained: compare GNSS and inertial sensors, explore key use-case differences, and learn how hybrid solutions improve accuracy, safety, and reliability.